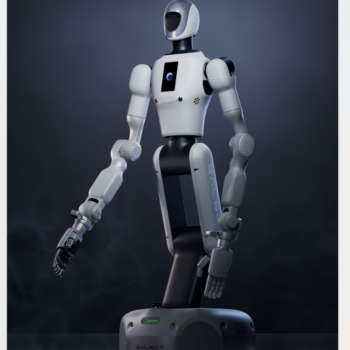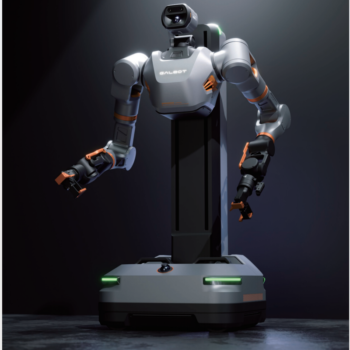

Galbot S1 Heavy-Duty Humanoid Robot
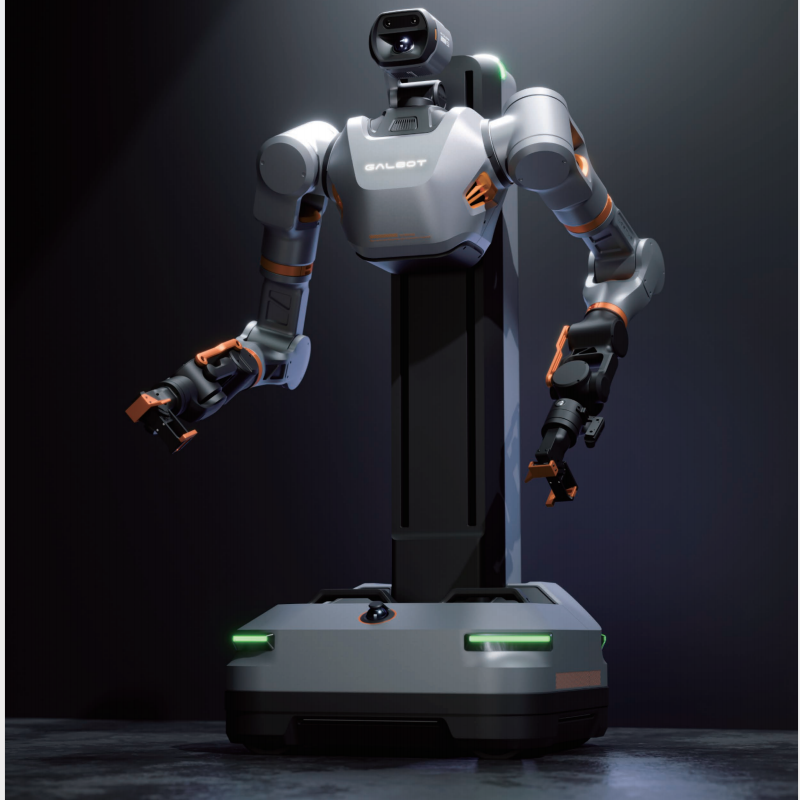
Galbot S1 is a heavy-duty humanoid robot platform developed for demanding industrial handling and automation tasks.
Combining a humanoid upper body, high-payload dual arms, multi-modal perception, autonomous mobile navigation, and a 4-wheel omnidirectional mobile base, Galbot S1 is designed to operate in industrial environments where conventional fixed automation can be difficult to deploy.
Its large operating envelope, dual-arm coordination, and high payload capacity make it particularly suitable for warehouse logistics, material handling, manufacturing, loading and unloading, and flexible industrial automation.
Key Features
1. High-Payload Industrial Handling
Galbot S1 is designed specifically for heavy-duty manipulation.
The robot supports:
25 kg single-arm payload
and up to:
50 kg total payload
This enables the robot to handle relatively heavy industrial materials and containers while maintaining a flexible humanoid manipulation configuration.
2. Large Working Space
Galbot S1 provides an extensive working envelope for handling tasks at different heights and positions.
| Capability | Specification |
|---|---|
| Maximum Robot Height | 1,793 mm |
| Arm Length | 920 mm |
| Lifting Stroke | 750 mm |
| Horizontal Working Space | 2,400 mm |
| Vertical Working Space | 2,390 mm |
| Single-Arm Payload | 25 kg |
| Total Payload | 50 kg |
The 750 mm lifting stroke and large horizontal/vertical working range allow the robot to address materials across a broad operating area.
3. 7-DoF Dual Arms
Galbot S1 uses two highly flexible arms with:
7 DoF × 2
The dual-arm configuration enables coordinated manipulation of larger or more complex objects.
Typical applications include:
- Material transfer
- Box handling
- Loading and unloading
- Industrial assembly
- Machine tending
- Two-handed manipulation
The system is designed to support autonomous dual-arm collaboration for more flexible industrial workflows.
4. Multi-Modal Perception
Galbot S1 integrates multiple sensing systems to perceive its surrounding environment and the objects being manipulated.
Head Perception
- Dual RGB cameras
- 3D LiDAR
Arm Perception
- Dual depth cameras
- Dual 6-axis force sensors
Mobile Base Perception
- Dual 3D LiDAR
This multi-modal sensing architecture provides environmental awareness for navigation, obstacle avoidance, object handling, and force-controlled manipulation.
5. Autonomous Navigation
Galbot S1 combines humanoid manipulation with an autonomous mobile platform.
The mobile base features:
4-wheel omnidirectional movement
with a maximum speed of:
1.5 m/s
This allows the robot to move flexibly through industrial environments and position itself for different handling tasks.
The system supports 3D LiDAR-based autonomous navigation and real-time obstacle avoidance, helping the robot operate safely around industrial facilities and other equipment.
6. Dual-Arm Collaborative Operation
Galbot S1 is designed to coordinate both arms while simultaneously controlling its mobile base.
This enables workflows such as:
Navigate → Position → Reach → Grasp → Lift → Transport → Place
The combination of mobile manipulation and dual-arm coordination makes Galbot S1 suitable for flexible industrial operations where fixed robotic arms may have limited workspace.
7. Industrial-Grade Computing
The system uses an AGX Orin 64GB computing platform with:
275 TOPS AI Computing Power
This provides the onboard computing capability required for perception, navigation, manipulation, and intelligent robot applications.
8. Long Operating Time & Hot-Swappable Batteries
Galbot S1 is designed for extended industrial operation.
Operating Time
Up to 8 hours
Battery
48 V / 30 Ah × 2
Charging Time
Approximately 2 hours per battery
The system supports quick battery replacement, allowing operators to replace batteries and reduce downtime during continuous operations.
This supports demanding workflows such as warehouse and manufacturing operations.
9. Industrial Interfaces & Accessories
Galbot S1 provides a range of standard accessories and expansion interfaces.
Standard accessories include:
- Wireless remote controller
- Wired charger
- Wireless emergency stop
Expansion interfaces include:
- USB 3.0 × 2
- Ethernet port
These interfaces provide flexibility for system integration and application development.
Industrial Applications
Warehouse & Logistics
Galbot S1 can be deployed for:
- Box handling
- Material transportation
- Loading and unloading
- Warehouse transfer
- Container handling
- Picking and placing
Its 50 kg total payload and large working range make it suitable for heavy material handling.
Manufacturing
The robot can support flexible manufacturing workflows including:
- Machine tending
- Material feeding
- Component handling
- Assembly assistance
- Workstation transfer
- Production-line logistics
Heavy Material Handling
With a 25 kg single-arm payload and 50 kg combined payload, Galbot S1 is designed for handling heavier objects that may exceed the capabilities of conventional lightweight service robots.
Loading & Unloading
The combination of mobile navigation, lifting capability, and dual-arm manipulation enables Galbot S1 to assist with loading and unloading tasks across different workstations.
Flexible Industrial Automation
Unlike traditional fixed robotic arms, Galbot S1 combines:
Mobile Base + Humanoid Arms + Multi-Modal Perception + Autonomous Navigation
This allows the robot to move between different work areas and perform multiple tasks using a single robotic platform.
Technical Specifications
| Category | Specification |
|---|---|
| Product Model | Galbot S1 |
| Product Type | Heavy-Duty Humanoid Robot |
| Maximum Height | 1,793 mm |
| Arm Length | 920 mm |
| Lifting Stroke | 750 mm |
| Horizontal Working Space | 2,400 mm |
| Vertical Working Space | 2,390 mm |
| Single-Arm Payload | 25 kg |
| Total Payload | 50 kg |
| Robot Weight | Approx. 320 kg |
| Operating Temperature | 0–40°C |
| Operating Humidity | 0–90% RH, Non-Condensing |
| Computing Platform | NVIDIA AGX Orin 64GB |
| AI Computing Power | 275 TOPS |
| Wireless Network | Wi-Fi 2.4/5 GHz |
| Bluetooth | Bluetooth 5.2 |
| Display | 7-inch Touchscreen |
| Speakers | 5W × 2 |
| Head Cameras | Dual RGB Cameras |
| Head LiDAR | 3D LiDAR × 1 |
| Arm Depth Cameras | Depth Cameras × 2 |
| Arm Force Sensors | 6-Axis Force Sensors × 2 |
| Base LiDAR | 3D LiDAR × 2 |
| Neck DoF | 2 |
| Arm DoF | 7 × 2 |
| Lifting DoF | 1 |
| Mobile Base | 4-Wheel Omnidirectional |
| Base Dimensions | 730 × 730 mm |
| Maximum Base Speed | 1.5 m/s |
| Operating Time | Up to 8 hours |
| Battery | 48V 30Ah × 2 |
| Charging Time | Approx. 2 hours per battery |
| Hot-Swap Battery | Supported |
| USB | USB 3.0 × 2 |
| Ethernet | Supported |
| Wireless Remote Controller | Standard |
| Wired Charger | Standard |
| Wireless Emergency Stop | Standard |
Why Choose Galbot S1?
50 kg Heavy-Duty Payload
Designed for industrial material handling with up to 25 kg per arm and 50 kg combined payload.
Large Working Envelope
Up to 2,400 mm horizontal and 2,390 mm vertical working space.
Mobile Manipulation
The omnidirectional mobile base allows the robot to move between different work areas instead of remaining fixed at a single workstation.
7-DoF Dual Arms
Two 7-DoF arms provide the flexibility required for complex manipulation and two-handed tasks.
Advanced Perception
RGB cameras, depth cameras, 3D LiDAR, and 6-axis force sensing provide multi-modal perception for navigation and manipulation.
8-Hour Operation
Dual 48V 30Ah batteries and hot-swappable battery support enable extended operation and reduced downtime.